
Physics engines translate mathematical constraints into the tactile reality of virtual worlds. By calculating collisions, forces, and rigid body dynamics in real time, these systems transform static assets into responsive environments. Whether handling complex particle interactions or simple character controllers, the choice of a simulation backend dictates the limits of your game design.
This guide dissects the architectural requirements of modern physics engines, providing a technical framework for evaluating simulation backends based on performance, hardware acceleration, and integration with modern Entity Component System (ECS) paradigms. We move beyond basic concepts to address the production-level trade-offs required for high-fidelity interactive software in 2026.
Architecture and Core Mechanics of Physics Engines
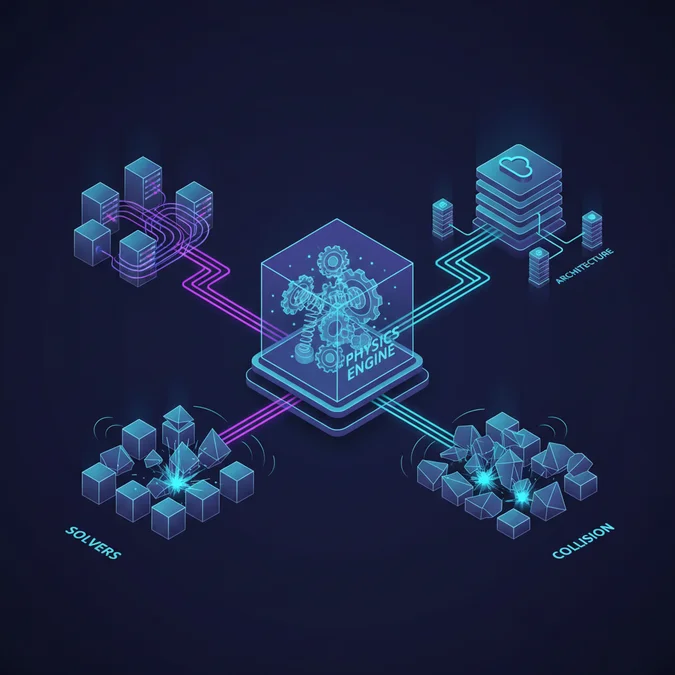
At the architectural level, physics engines operate as discrete time-steppers that cycle through three primary phases: collision detection, constraint solving, and integration. The efficiency of these phases determines the stability of the simulation.
// Simplified integration loop for a rigid body

void UpdatePhysics(RigidBody& body, float dt) {

 Vector3 force = CalculateForces(body);

 body.velocity += (force / body.mass) * dt;

 body.position += body.velocity * dt;

 ResolveCollisions(body);

}
Collision detection is typically split into a broad-phase (using spatial partitioning like BVH or Octrees) and a narrow-phase (using GJK or SAT algorithms). The constraint solver then applies impulses to satisfy non-penetration conditions.
Technical Note: Numerical instability often arises from floating-point errors. Using fixed time-steps is mandatory to maintain deterministic behavior across different hardware configurations.
Game Physics Engine Taxonomies and Ecosystems
Choosing a game physics engine requires mapping the desired fidelity against the deployment target. The landscape ranges from high-performance native C++ libraries to lightweight WebAssembly modules.
| Category | Primary Target | Key Strength |
|---|---|---|
| Native Rigid Body | Desktop/Console | Deterministic Stability |
| GPU Compute | Large Scale Particles | Massive Parallelism |
| Web-based | Browser/Mobile | Low Overhead |
Selection Checklist:
- Dimensionality: Are you restricted to 2D manifolds or full 3D volumes?
- Determinism: Does the engine support lock-step networking for multiplayer?
- Integration: Does the engine provide a native C API or direct bindings to ECS?
Implementing Physics in ECS Frameworks
Integrating simulation modules into an ECS (Entity Component System) architecture requires a data-oriented design. Instead of object-oriented hierarchies, physics data should reside in contiguous memory blocks to maximize CPU cache locality.
- Define a PhysicsComponent containing mass, velocity, and friction properties.
- Initialize a TransformSystem that updates entity positions based on current velocity.
- Implement a CollisionSystem that processes component buffers to resolve overlaps.
// Data-oriented component update
struct PhysicsSystem: System {
void Update(EntityManager& em, float dt) {
auto entities = em.query
for(auto& e: entities) {
e.position += e.velocity * dt;
}
}
};
Performance Benchmarking: CPU versus GPU Simulation
The choice between CPU and GPU simulation hinges on the nature of the physics workload. CPU solvers excel at complex constraint chains and articulated bodies, while GPU compute pipelines dominate in high-density particle and fluid scenarios.
| Metric | CPU Simulation | GPU Simulation |
|---|---|---|
| Latency | Low (Serial) | High (Latency-hiding) |
| Throughput | Moderate | Extreme |
| Best For | Character/Vehicle | Fluids/Particles |
Warning: Moving data between CPU and GPU memory (PCIe bus) introduces significant overhead. Avoid frequent read-backs unless strictly necessary for gameplay logic.
Technical Selection Matrix for 2026 Projects
Use this matrix to align technical requirements with engine capabilities. Modern projects demand modularity; avoid engines that force an all-or-nothing monolithic architecture.
| Requirement | Recommended Approach |
|---|---|
| High-Fidelity 3D | Native C++ Physics SDK |
| Browser-based | WASM-compiled Simulation |
| Massive Scale | Compute-Shader Driven |
Engine Selection Checklist:
- Does the engine support multi-threading at the solver level?
- Is the collision detection algorithm customizable?
- Are there existing integrations for your specific engine (e.g. Bevy, Unity)?
Frequently Asked Questions
What are the primary differences between physics engines?
Physics engines differ primarily in their integration methods, collision detection algorithms, and performance targets. Some focus on rigid body stability using constraint solvers, while others prioritize soft body dynamics or fluid simulation, often optimized differently for CPU-bound serial tasks or highly parallel GPU compute pipelines.
How do I select the right game physics engine for my project?
Selecting a game physics engine requires evaluating your target platform, dimensionality requirements, and performance overhead. For web-based projects, prioritize lightweight JavaScript or WebAssembly libraries. For industrial-grade 3D applications, evaluate engines based on their support for ECS architectures and hardware-accelerated physics processing capabilities.
Selecting the right simulation backend is a balance between performance, stability, and development velocity. By prioritizing data-oriented design and understanding the hardware constraints of your target platform, you can ensure your simulation remains stable under heavy load.
Evaluate your project against the provided matrix and focus on decoupling your physics simulation from game logic to maintain architectural flexibility for future iterations.